Autonomous underwater vehicles
Out of contact for hours to months, with no way to swap a board.
“Capability is a depleting resource to be spent, not a fixed budget to be defended.”
Whitepaper, §5
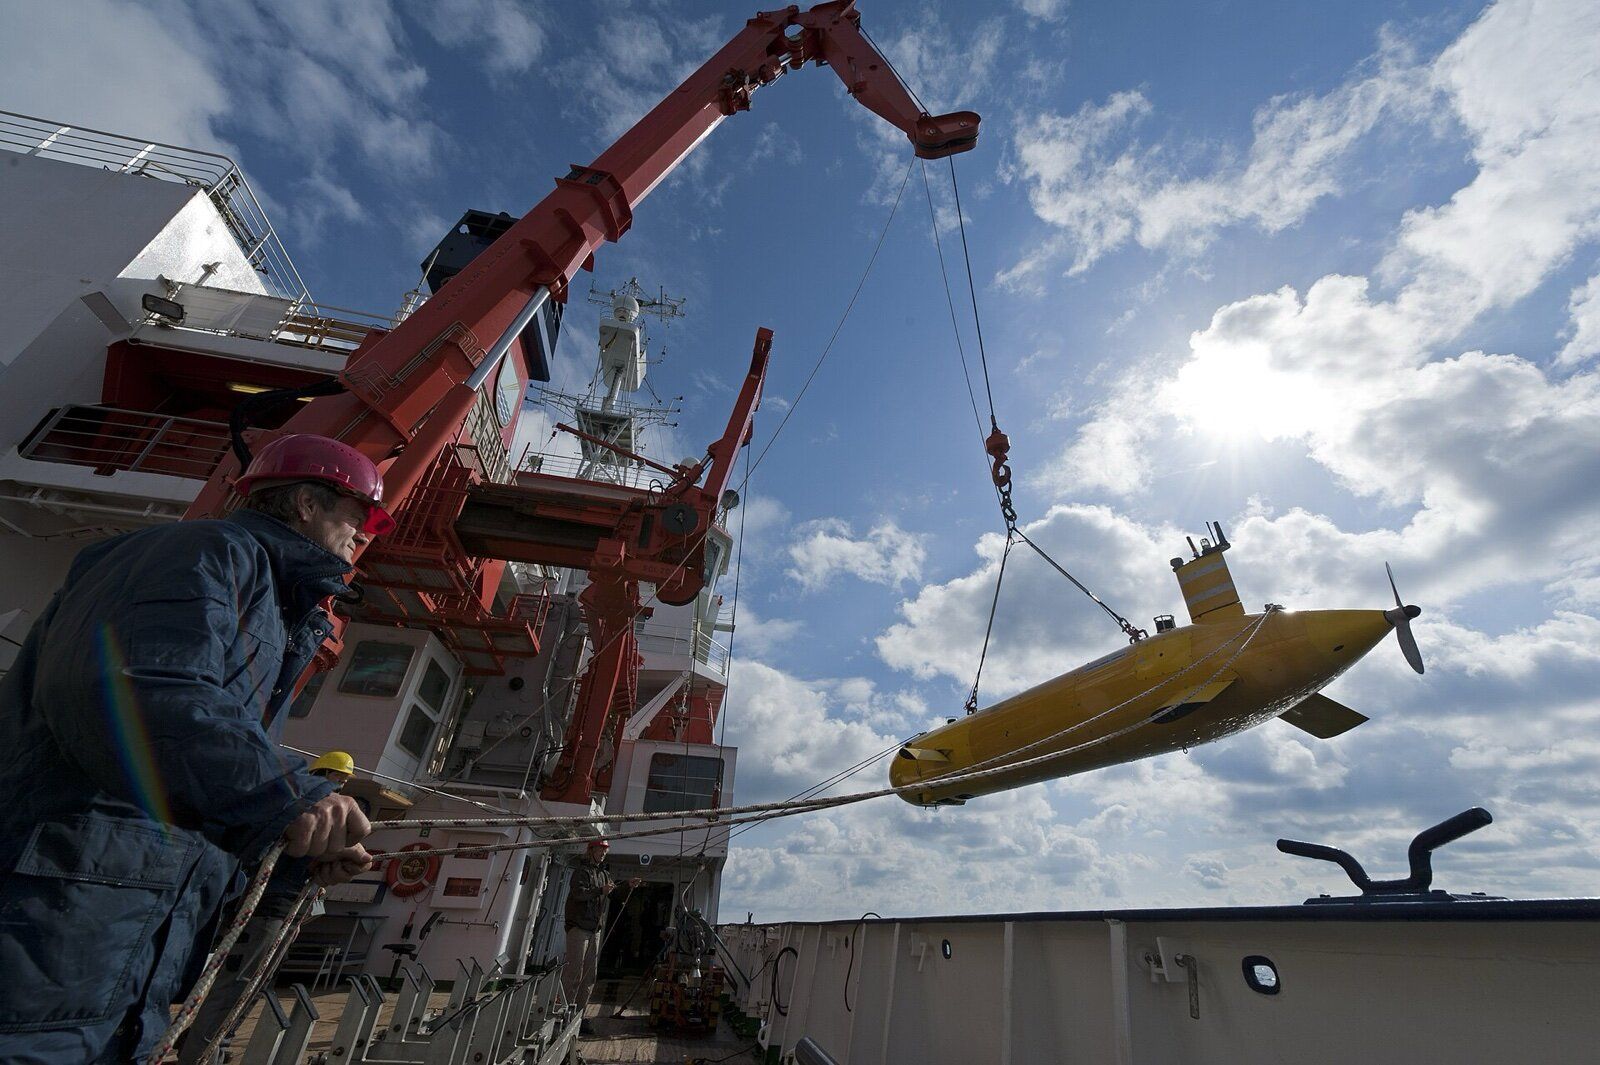
An AUV works with finite power, ageing hardware and almost no communication until it surfaces. The whitepaper names it as one of the closest cousins of a deep-space probe.
Mru Field runs on the processors already in the equipment. When one fails and nobody can come, it continues on the ones left and delivers only results it can check. Status: decision core at TRL 3; first field pilot planned for 2027.
01
No one to ask
When two computers disagree, there is no operator to say which one is right.
02
The link is thin
Bytes per message, or nothing until the next window. Problems have to be solved on site.
03
Computers fail one by one
Radiation, heat and age take out processors and memory. Nothing is replaced until the next visit.
Three computers. Then two. Then one, still working.
Most redundant systems stop when they lose their majority. Mru Field steps down instead, and says which mode it is in.
3 alive · vote
Three computers vote. One bad result is outvoted.
2 alive · compare
Two compare. A known-answer test finds the faulty one.
1 alive · self-check
The last one checks its own work and brings the mission home, at half speed.
Power
Batteries
Link
Acoustic, or none until it surfaces
Visits
At each recovery
Service life
Days to months per mission
Questions
Does Mru Field need new hardware?
No. It is software for the processors you already deploy. It runs beside your control code and decides which computer to trust as parts fail.
Does it replace our autonomy stack?
No. It sits underneath. It decides which computer to trust, so your autonomy keeps running when one of them fails.
How do we start?
Use the form below. We first model your hardware and show what each redundancy design returns over its whole life. Then we plan a pilot on your own equipment.